Digital Speleology (Vale)
Autonomy for the Unitree Go2VerLab · UFMG
Undergraduate student researcher · Scholarship
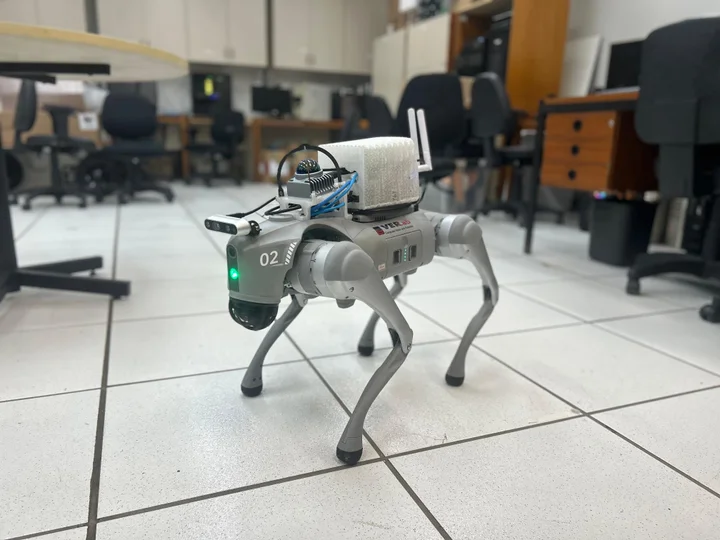
I work on making the Unitree Go2 reliable in unstructured environments, especially caves. I developed its autonomy stack in simulation and on the robot, integrating networking, mapping, perception, and Nav2 navigation. My current work focuses on detecting LiDAR-inertial odometry failures using available sensor data, managing map growth and accumulated errors during long-duration navigation, and contributing to a reinforcement-learning-based perception algorithm.
I also built a Docker-based remote base station using ROS 2, CycloneDDS, and Zenoh, and designed a modular sensor and communications backpack in FreeCAD and SOLIDWORKS. I co-authored “A Handheld System for Three-Dimensional Mapping of Harsh Natural Caves,” accepted for LARS 2026, adapting BIEVR-LIO and FAST-LIO2 to enable a fair comparison.